Compact geometry
Diameter, length and shaft-passage options adapted to the joint volume simplify mechanical integration.
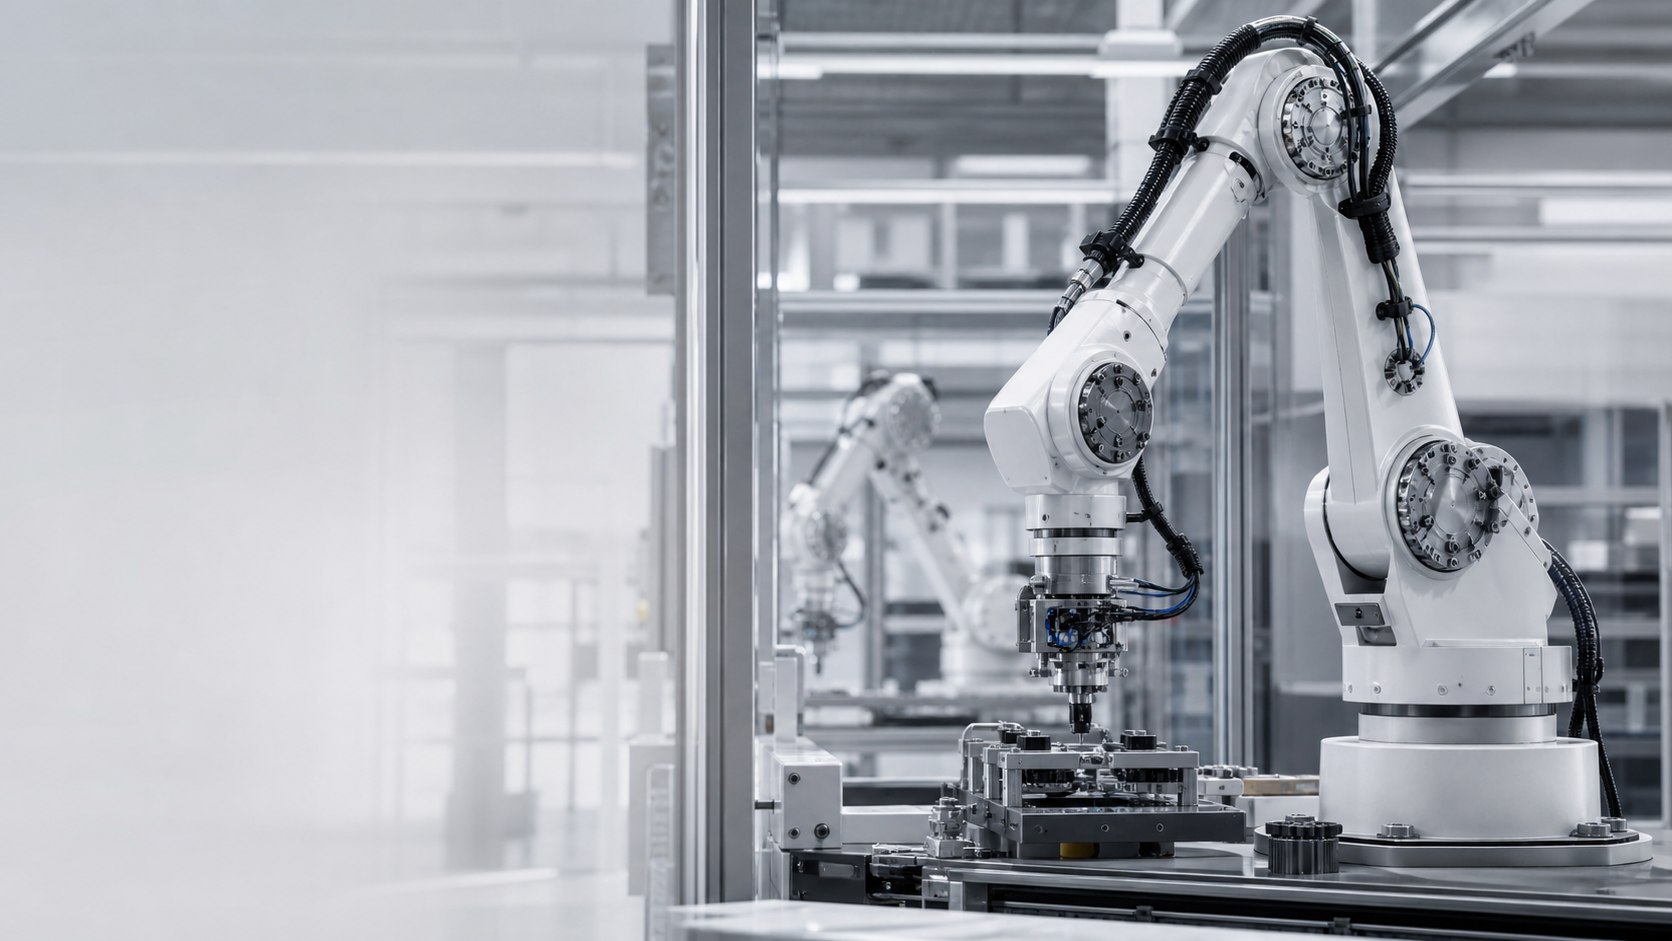
Industrial automation / 02
Core Slip slip ring solutions carry power, control and data through rotating joints in multi-axis robots without restricting their range of motion.
Cable twisting in robot joints limits movement, cycle speed and maintenance planning. A slip ring turns the rotating joint into a continuous electrical interface.
Core Slip architecture is sized around the robot's load, axis geometry, speed profile and communication protocol.
Diameter, length and shaft-passage options adapted to the joint volume simplify mechanical integration.
Contact and bearing structures selected for repeated acceleration, deceleration and continuous rotation.
Combine motor power, encoder, control and industrial data lines in a single rotating interface.
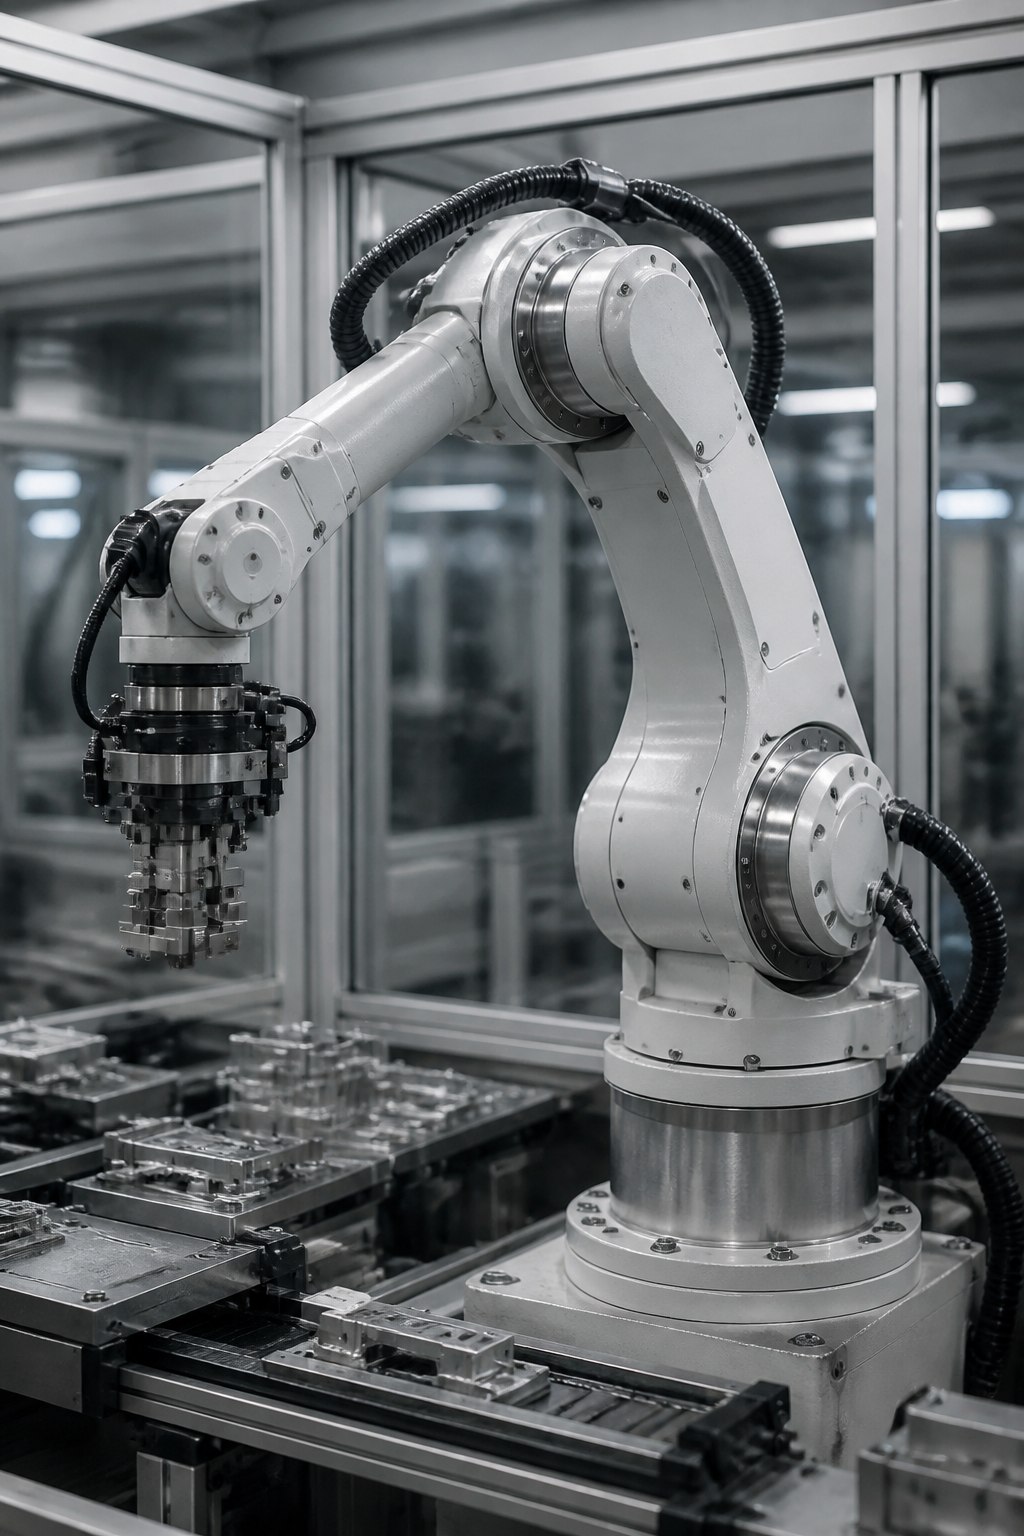 Rotating joint
Motion architecture
The rotary interface frees the robot programme from cable-winding limits and supports more consistent cycles in processes that require continuous rotation.
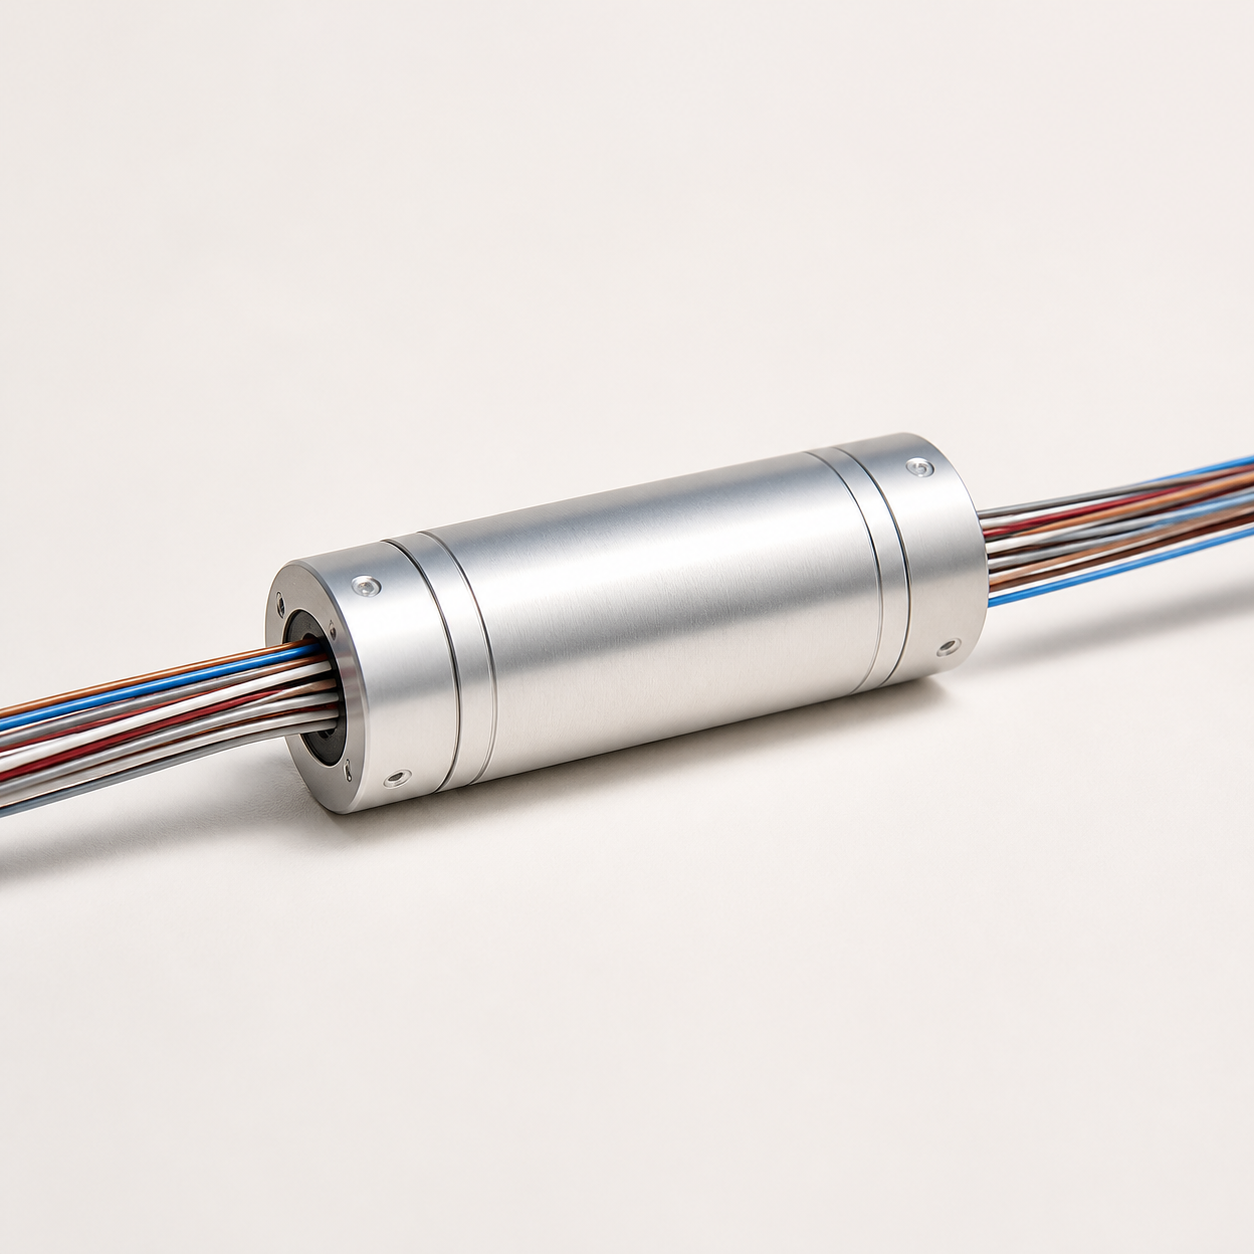 Compact solution
Space efficiency
A compact slip ring brings the channels needed by end effectors, rotating fixtures and space-limited joints together in a minimal mechanical footprint.
A robotics slip ring is considered for transmitting power and signals to a rotating joint or end effector. In applications requiring continuous rotation, cable winding and twisting can constrain the design. A slip ring addresses this electrical interface; it does not by itself remove the robot’s mechanical limits or meet every control system requirement. Assess the need separately for each axis.
Installation space, total moving mass, speed profile and duty cycle are initial design inputs. List power, sensor and communication channels separately; describe protocol requirements rather than only wire count. For compact slip ring selection , consider the capsule family, or the through-bore family when a shaft must pass through the centre. Plan cable exits and removal for servicing alongside the robot joint layout.
Let's discuss your robotics project
Share the axis geometry, speed range, channel and protocol requirements. The Core Slip team will help define the right solution for your robot.
Get in touch